GenerativeDynamics
Generative dynamics on manifold.
For robotics: Planning. Control. Learning.
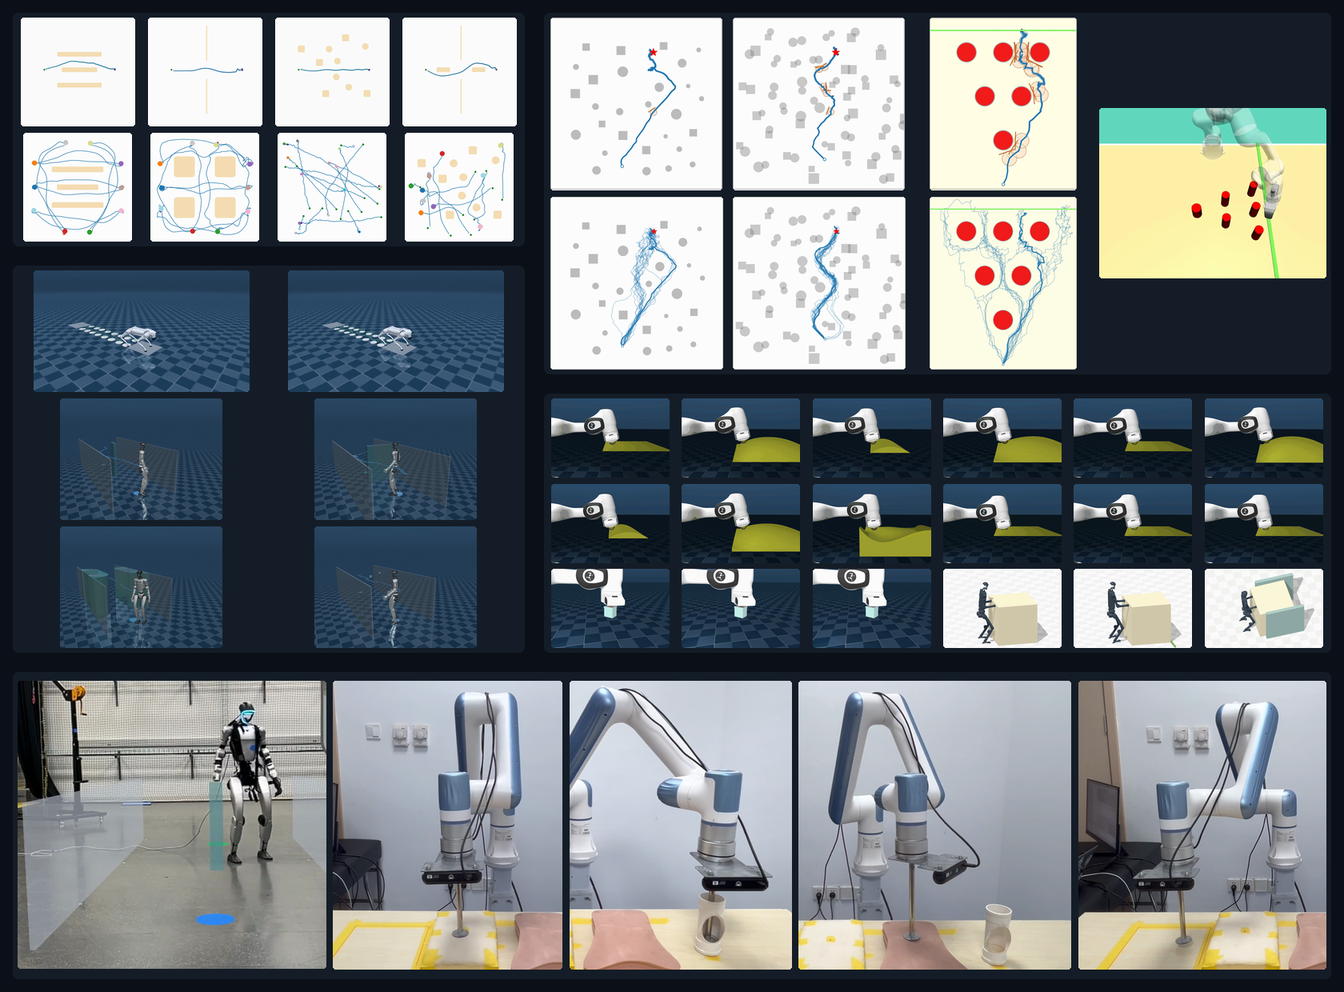
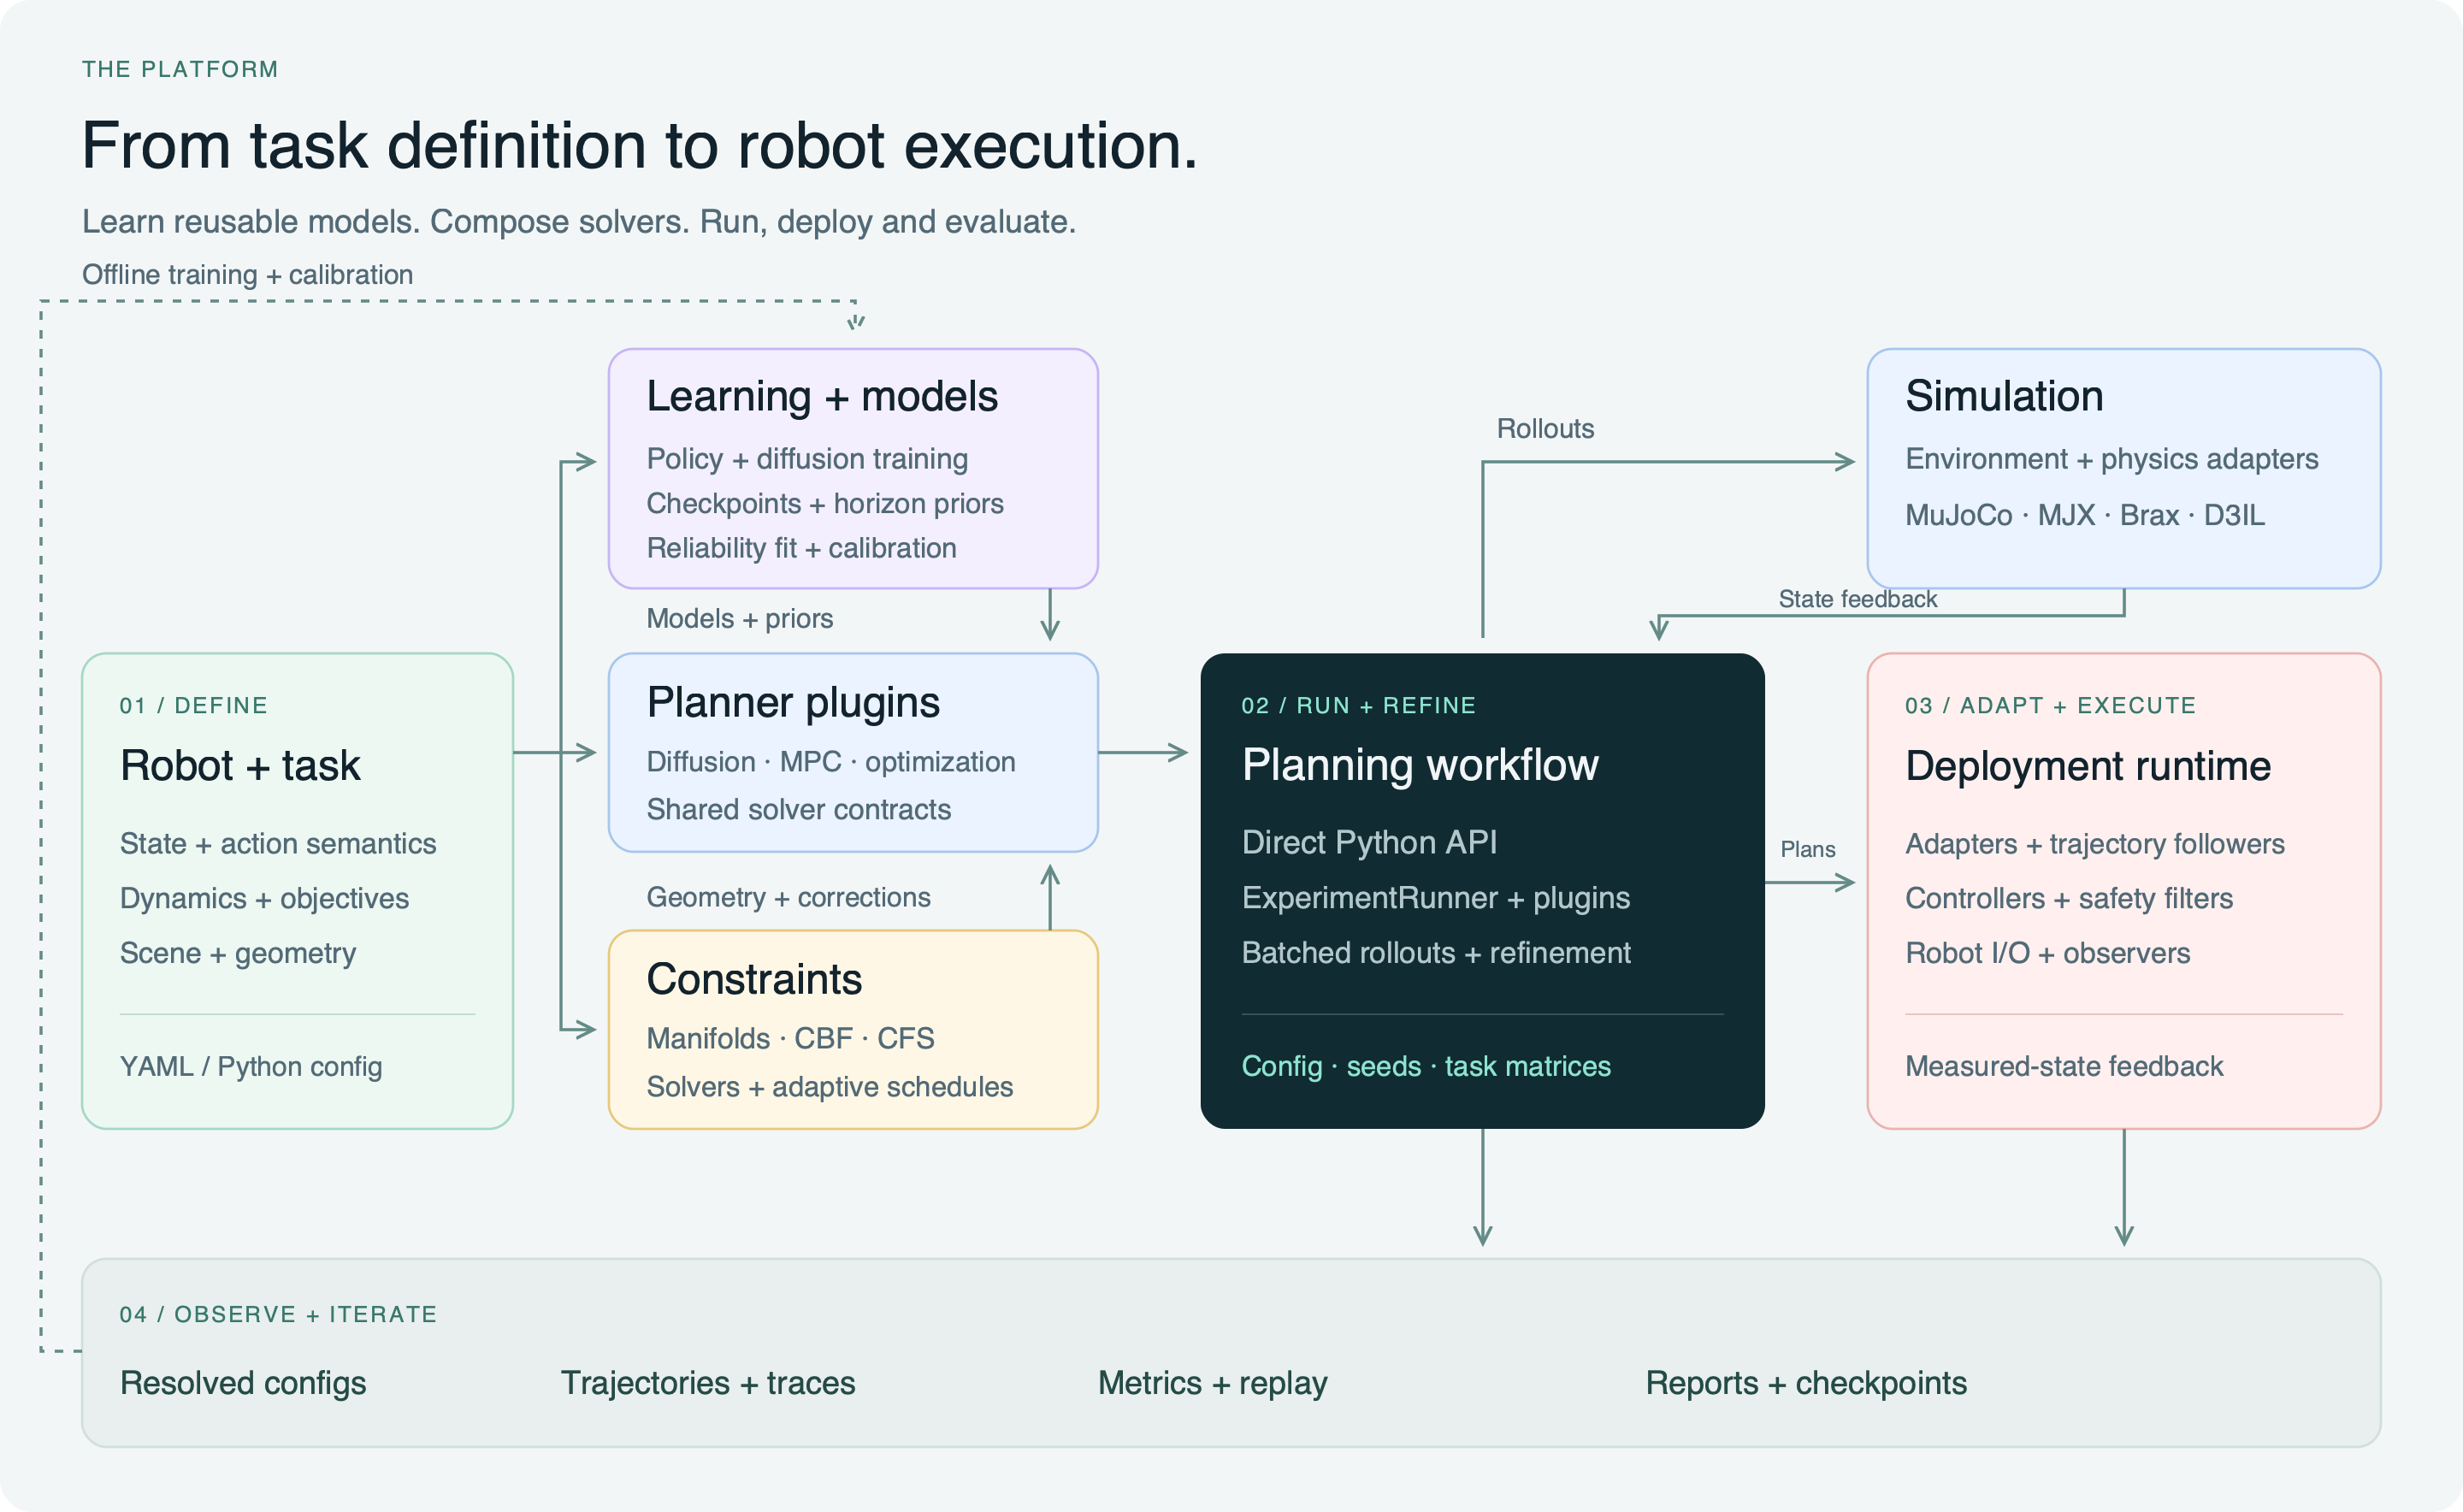
Train reusable policy priors, learn trajectory diffusion models, and perform model-based generative inference with dynamics, manifold geometry and constraints. Connect the resulting plans to closed-loop control through shared task, solver and execution interfaces.
Watch the full-quality video · Explore the task recipes
🧩 Build with reusable components
| Feature | What you can use |
|---|---|
| 🧠 Robot learning | PPO/SAC training and checkpoint reuse; PPO horizon priors for MGA. |
| ✨ Generative models | Learned trajectory diffusion, model-based generative inference and composable reverse transports. |
| Planner plugins | MDOC, MD-COAS, 2GO, MGA and comparison algorithms through shared task and solver interfaces. |
| Batched constraints | Candidate evaluation, CBF/CFS correction and manifold feedback inside generative inference; see the batch workflow. |
| Geometry and constraints | Convex primitives, meshes, signed-distance geometry, collision constraints, state/action limits and constraint schedules. |
| Robot task composition | Semantic robot profiles, task objectives, dynamics and scene geometry kept separate from planner implementations. |
| Simulation adapters | MuJoCo, MJX, Brax and D3IL integrations with recipe-specific dependencies. |
| Execution components | Receding-horizon planning, followers, controllers, governors, safety filters and robot I/O. |
| Experiment tooling | Seeded configurations, resumable task matrices, metrics, trajectories, reports and observer plugins. |
| Compute | JAX-first planning with CPU setup and CUDA installation paths; device support is qualified per planner. |
🧪 Explore our algorithms
| Algorithm | Start building |
|---|---|
| MDOC | Run the planar planning component with configs/single_2d/mdoc.yaml; see the original multi-robot project for its CBS application. |
| MD-COAS | Explore constrained diffusion and adaptive scheduling with configs/single_2d/mdcoas.yaml, then D3IL arm avoidance with configs/d3il_avoiding/mdcoas.yaml. |
| 2GO | Plan quadruped stepping stones and humanoid corridor motion; begin with the humanoid corridor recipe. |
| MGA | Reuse learned policy priors for generative motion–impedance control in peg insertion and surface scanning. |
The algorithm catalogue links the papers, explains each planner and maps published names to configuration keys.
🌍 Environments and constraints
Browse six environment families and the constraint catalogue: CBF/CFS filters, adaptive scheduling, and closed-form, JAXopt OSQP, OSQP and CVXOPT numerical solvers.
🚀 Start here
| Goal | Guide |
|---|---|
| Install the package and optional simulators | Installation |
| Use an environment and planner in your own Python loop | Direct Python example |
| Run JAX planners on Linux/NVIDIA | GPU workflows |
| Use isolated CPU or NVIDIA GPU environments | Docker |
| Initialize pinned robot descriptions and meshes | MuJoCo Menagerie |
| Save trajectories, metrics and multi-seed experiments | First experiment |
| Train models and reuse learned priors | Learning workflows |
| Choose a paper algorithm and task | Recipes |
| Understand or extend the interfaces | Architecture · Plugin development |
| Check support or upcoming integrations | Compatibility · Roadmap |
📍 Release status
V1 is JAX-first and includes six task families. Dedicated Torch integrations support DPCC and SafeDiffuser; broader Torch support and Rust/C++ backends are planned. MGA GPU qualification and humanoid walking/push are follow-up priorities. See the roadmap, compatibility matrix and V1 scope for the current release boundaries.