Explore original result figures, comparison tables, and robot demonstrations. Each work connects its behavior to the experiments reported in the paper.
2GO and hardware clips preserve original source timing; other clips may be re-timed for presentation. Planning success, governed simulation execution, and qualitative hardware evidence have different evaluation settings. Quantitative results and their protocols are documented on each research page.
SIMULATION
MDOC / Multi-robot coordination
Multi-robot coordination
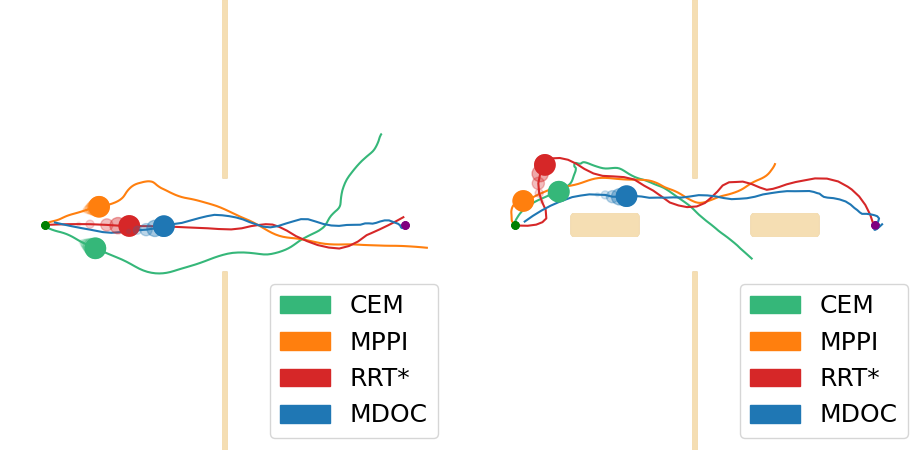
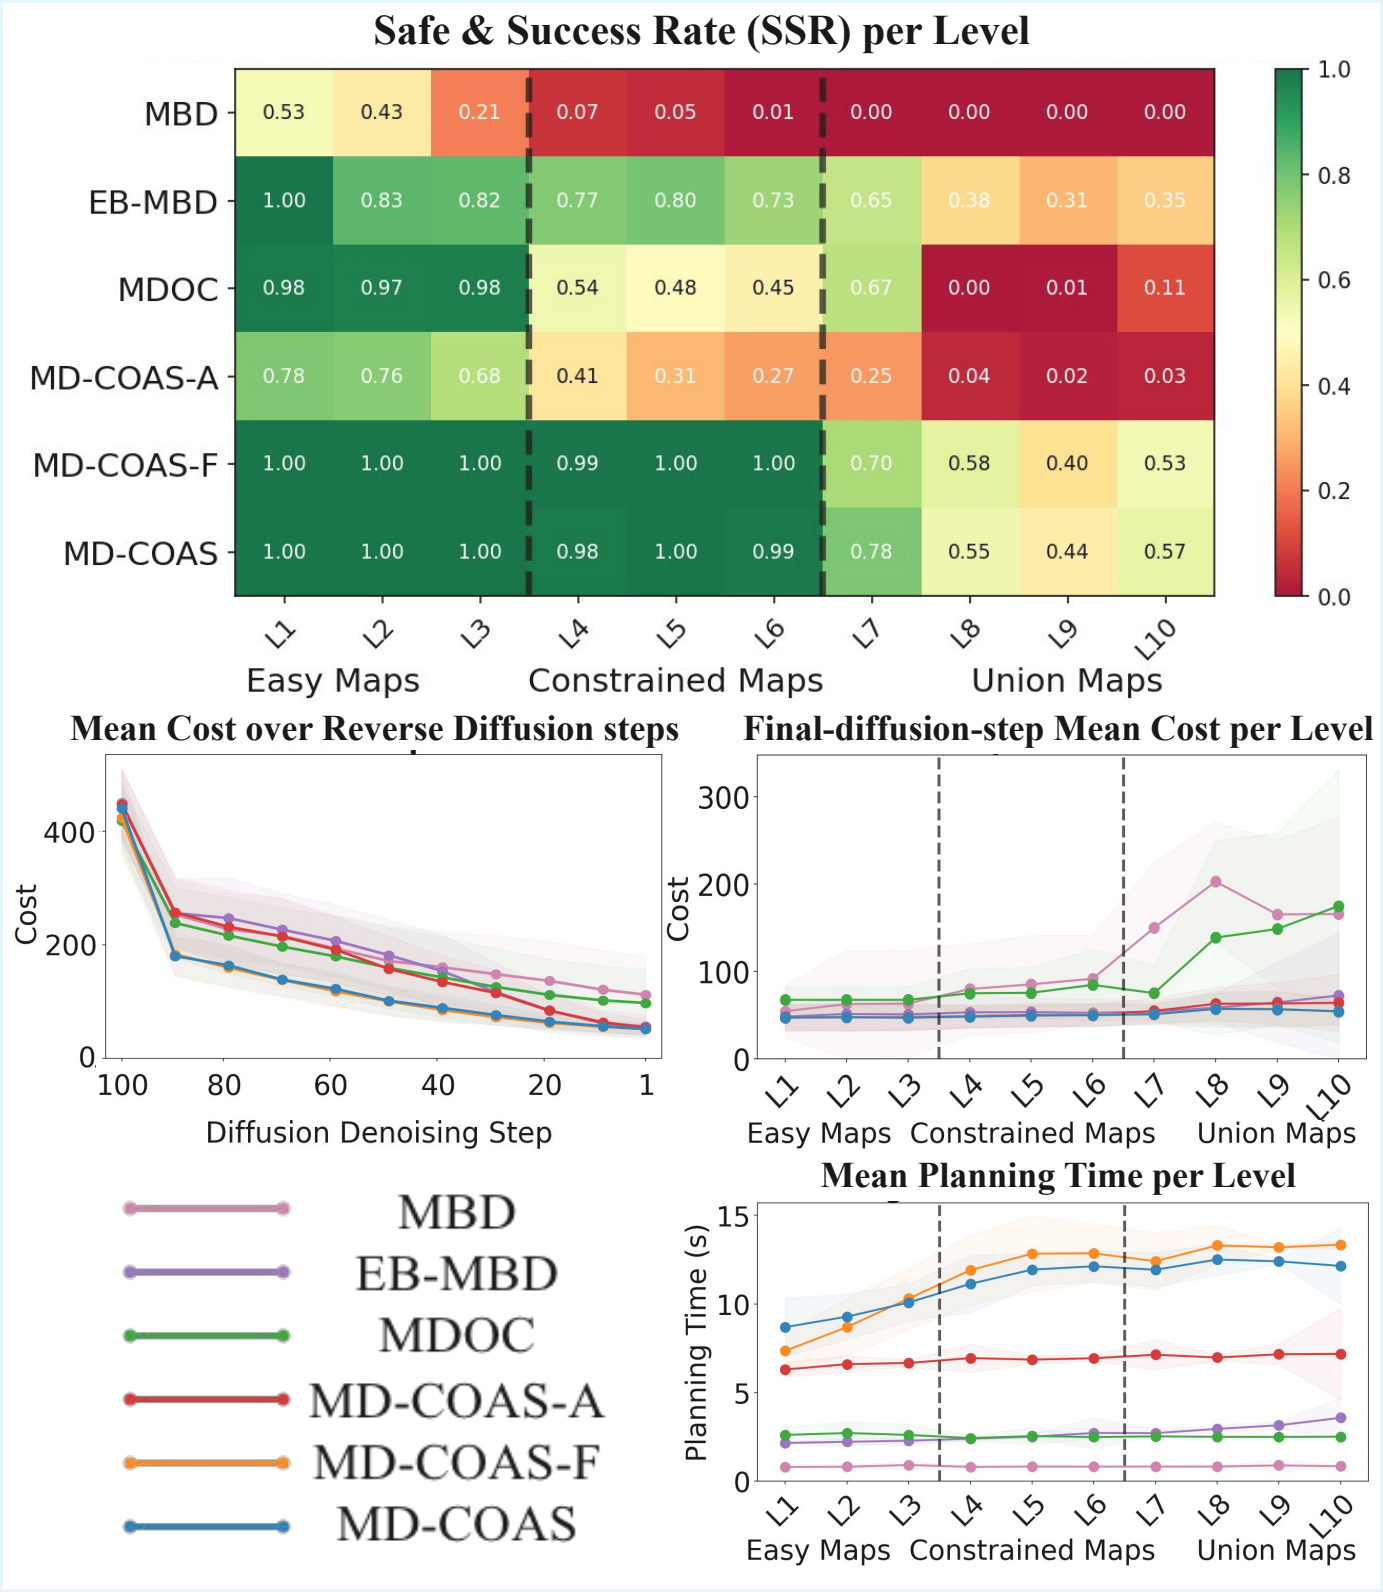
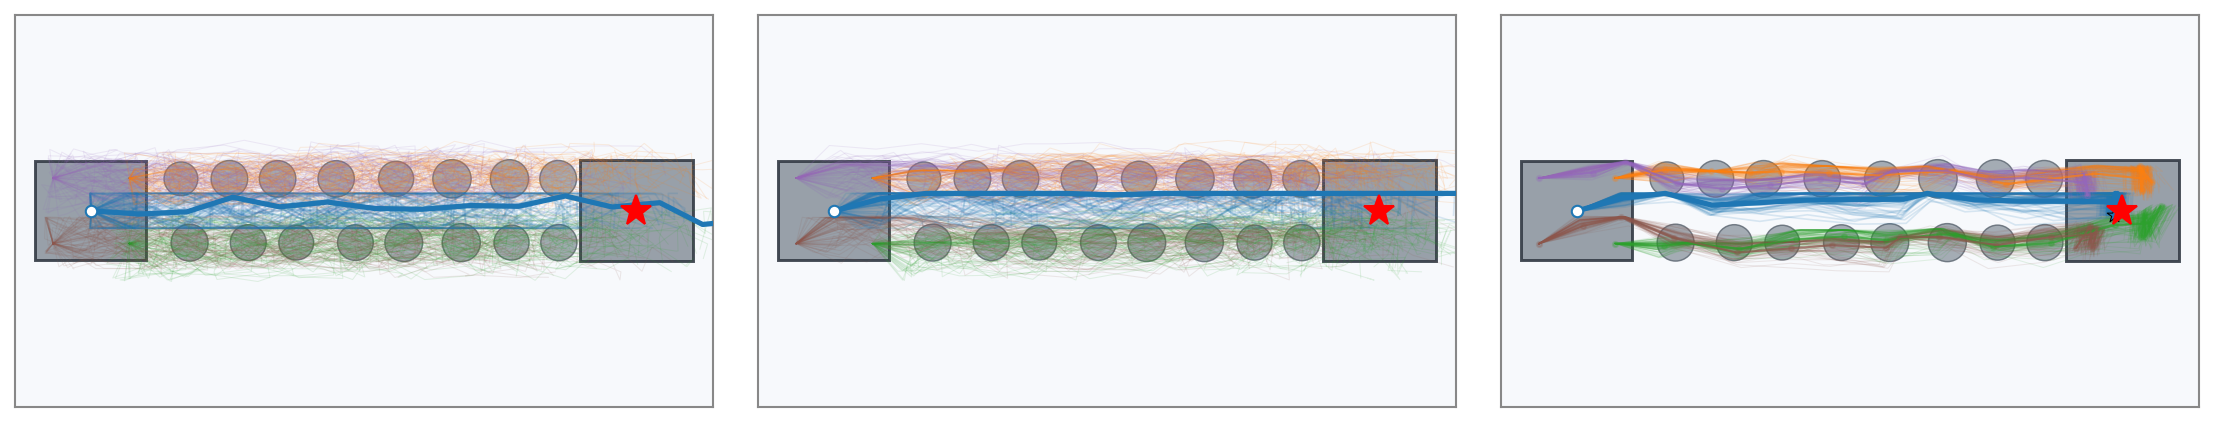
MDOC-CBS coordinates multiple robots in a constrained scene.
Simulationoriginal-mdoc-project
Playback and experimental context
Source excerpt rescaled to 6.0 seconds; looped, silent; not real-time execution or latency evidence.
Unitree H1 pushes a box forward from a fixed stance.
SimulationPaper demonstration · V1 deferred
Playback and experimental context
Original GIF timing preserved, including the final 800 ms hold; looped and silent. Repeated frames preserve source timestamps at 50 fps. Source animation timing is not a physical real-time benchmark.
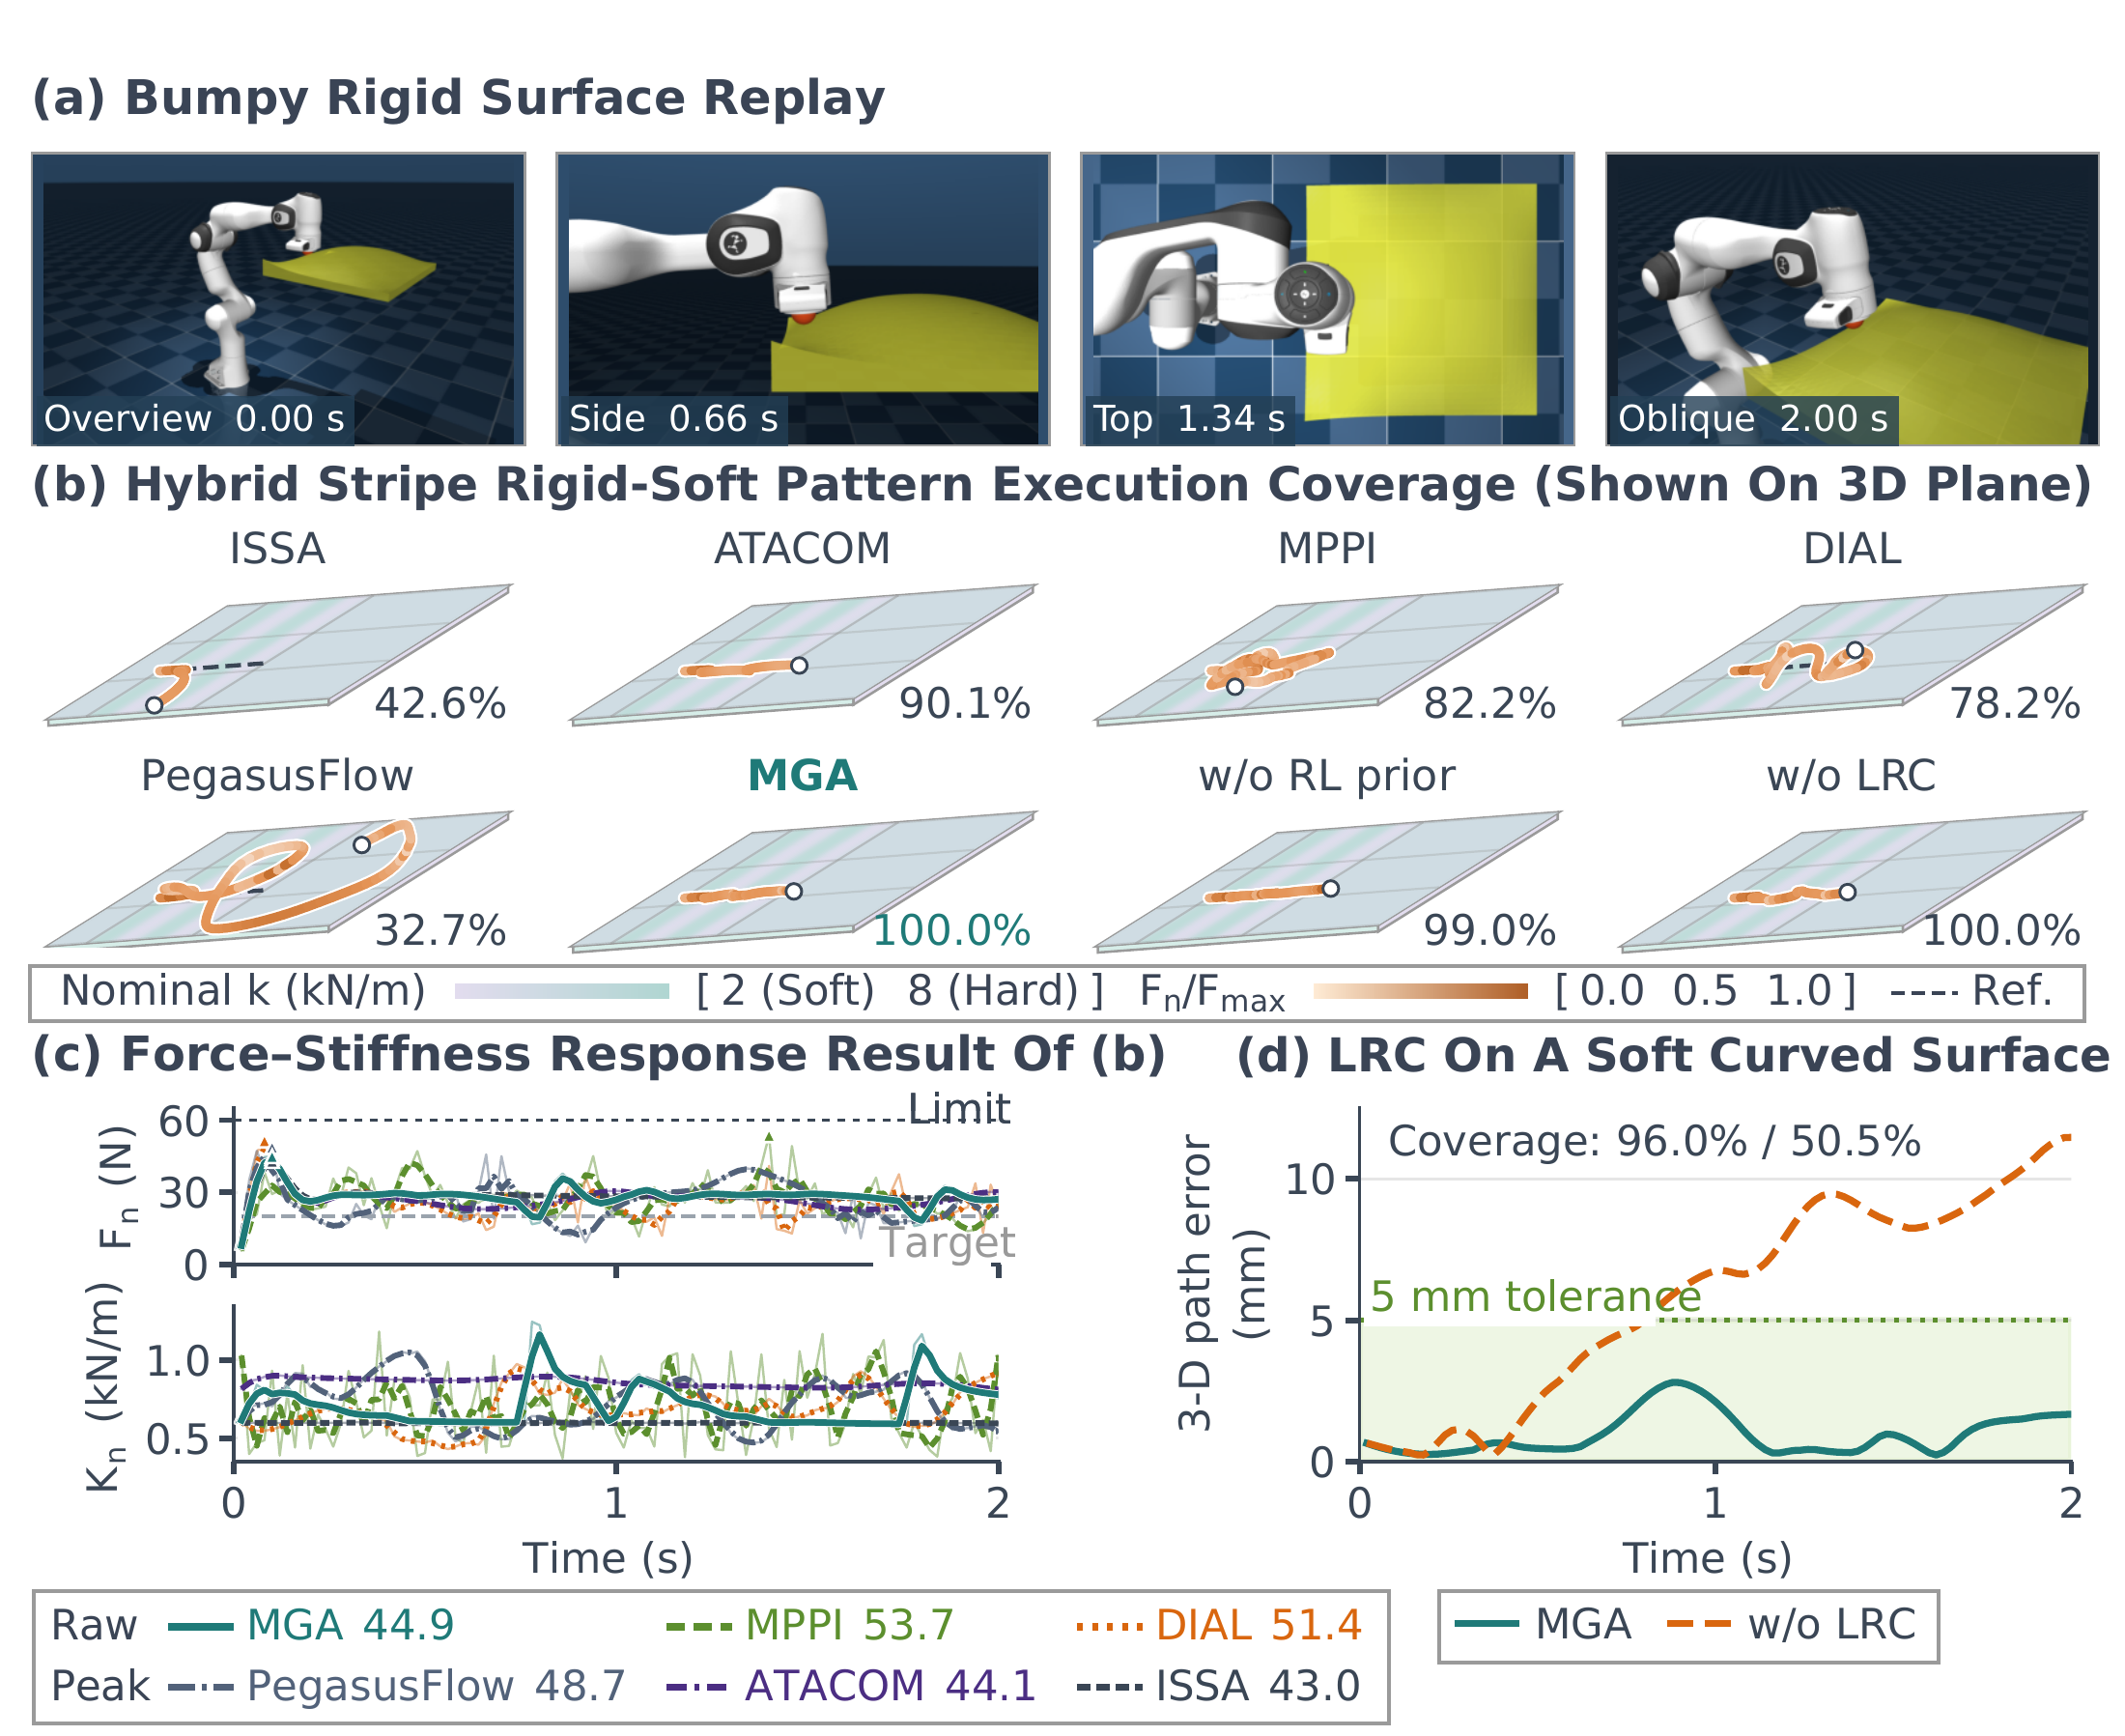
MGA Unitree H1 simulation from the paper supplement. Humanoid pushing remains deferred in the current framework release; this clip does not establish a qualified V1 reproduction path.
Unitree H1 regulates contact force against a stationary box.
SimulationPaper demonstration · V1 deferred
Playback and experimental context
Original GIF timing preserved, including the final 800 ms hold; looped and silent. Repeated frames preserve source timestamps at 50 fps. Source animation timing is not a physical real-time benchmark.
MGA Unitree H1 simulation from the paper supplement. Humanoid pushing remains deferred in the current framework release; this clip does not establish a qualified V1 reproduction path.
Unitree H1 adjusts contact to free a box from a narrow passage.
SimulationPaper demonstration · V1 deferred
Playback and experimental context
Original GIF timing preserved, including the final 800 ms hold; looped and silent. Repeated frames preserve source timestamps at 50 fps. Source animation timing is not a physical real-time benchmark.
MGA Unitree H1 simulation from the paper supplement. Humanoid pushing remains deferred in the current framework release; this clip does not establish a qualified V1 reproduction path.